
N° 01
Smart Greenhouse: Watering by Soil Moisture
A mini greenhouse that runs a pump when soil moisture drops and shows the readings on a display.
A robot that follows a black line, finds the “injured” cube and carries it to the safe zone.
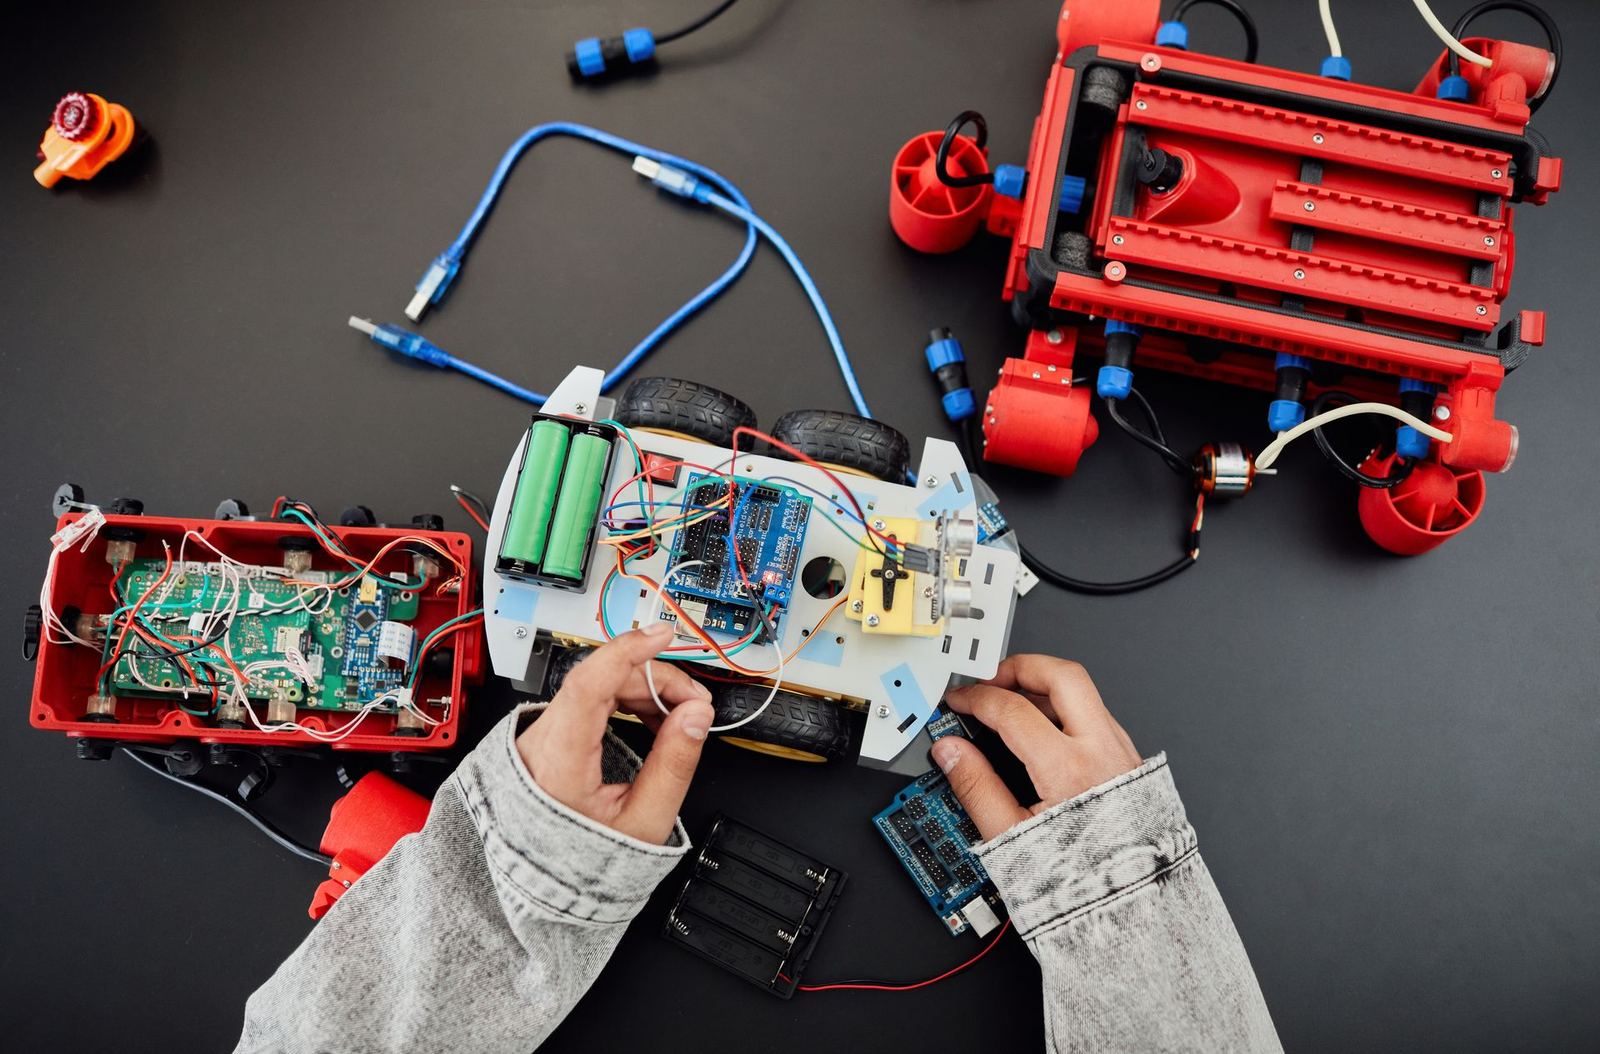
The LEGO Robotics Engineering group’s term project was built around a rescue scenario. The robot follows the line with two colour sensors, picks a direction at junctions according to a green marker and uses its gripper arm to carry the cube at the end of the track to the safe zone.
Students first built a robot that zigzagged with a single sensor, then discovered the idea of proportional control with two sensors. Three different mechanisms were tried for the gripper arm, and the design giving the firmest grip with the fewest parts was chosen. Every trial was logged in the engineering notebook with its time and success rate.
The robot came second in the 9-12 category of the Devrecik Mini Robot League. After the competition the team added a code block that automatically calibrates the colour sensor before every run to stop the robot hesitating at junctions. This small change cut the average lap time by four seconds.
N° 01
A mini greenhouse that runs a pump when soil moisture drops and shows the readings on a display.
N° 02
A wireless classroom voting system built with micro:bit boards that shows results instantly as a chart.
N° 03
A cane attachment that detects obstacles ahead with an ultrasonic sensor and warns by vibration.